Guillaume Durandau, Ph.D.
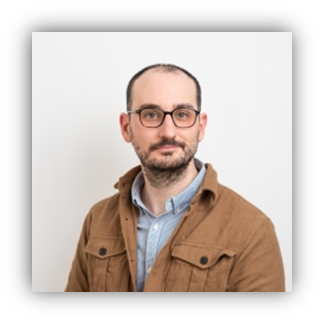
Professeur(e) adjoint(e), Département de génie mécanique, Université McGill
Membre chercheur régulier
Hôpital juif de réadaptation (HJR) | Santé Québec Laval
Autre(s) responsabilité(s) au CRIR :
Responsable de l'unité thématique 1 de l'axe 1
Parcours académique
- Maitrise de recherche, Électricité, M.Eng., France, 2013
- Maitrise de recherche, Électricité, Université de Sherbrooke,Canada, 2015
- Doctorat, Biomécanique et robotique, Université de Twente, Netherlands, 2020
Axe de recherche
Axe 1: Fonctions et activités sensorielles, motrices et cognitives
Unité thématique de recherche
Unité thématique 1. Mécanismes fonctionnels
Laboratoire de recherche
-
Laboratoire de neuromechanique et de contrôle robotique (NeuRoC Lab)
https://crir.ca/recherche/laboratoires-2-2/laboratoires-2/laboratoire-de-neuromechanique-et-de-controle-robotique-neuroc-lab/
Intérêts de recherche
- Biomécanique des mouvements;
- Modélisation neuromusculosquelettique;
- Robotique portable (exosquelette, prothèse);
- Contrôle neuronal des mouvements
Publications
- Wang, H., Basu, A., Durandau, G., Sartori, M. (2023). A Wearable Real-time Kinematic and Kinetic Measurement Sensor Setup for Human Locomotion. Wearable technologies, 4, e11. [doi] LIBRE ACCÈS
- Moya-Esteban, A., Durandau, G., van der Kooij, H., Sartori, M. (2023). Real-time lumbosacral joint loading estimation in exoskeleton-assisted lifting conditions via electromyography-driven musculoskeletal models. Journal of biomechanics, 157, 111727. [doi] LIBRE ACCÈS
- Mahdian, Z. S., Wang, H., Refai, M. I. M., Durandau, G., Sartori, M., MacLean, M. K. (2023). Tapping Into Skeletal Muscle Biomechanics for Design and Control of Lower Limb Exoskeletons: A Narrative Review. Journal of applied biomechanics, 39(5), 318–333. [doi] LIBRE ACCÈS
- CAGGIANO, Vittorio, WANG, Huawei, DURANDAU, Guillaume, et al. A contact-rich simulation suite for musculoskeletal motor control. Proceedings of Machine Learning Research vol, 2022, vol. 168, p. 1-16. [doi] LIBRE ACCÈS
- DURANDAU, Guillaume, RAMPELTSHAMMER, Wolfgang F., VAN DER KOOIJ, Herman, et al. Neuromechanical model-based adaptive control of bilateral ankle exoskeletons: biological joint torque and electromyogram reduction across walking conditions. IEEE Transactions on Robotics, 2022, vol. 38, no 3, p. 1380-1394. [doi] LIBRE ACCÈS